Project: AIMS AUV co-development
Client: Australian Institute of Marine Science
Scope: Prelim Design → Operational
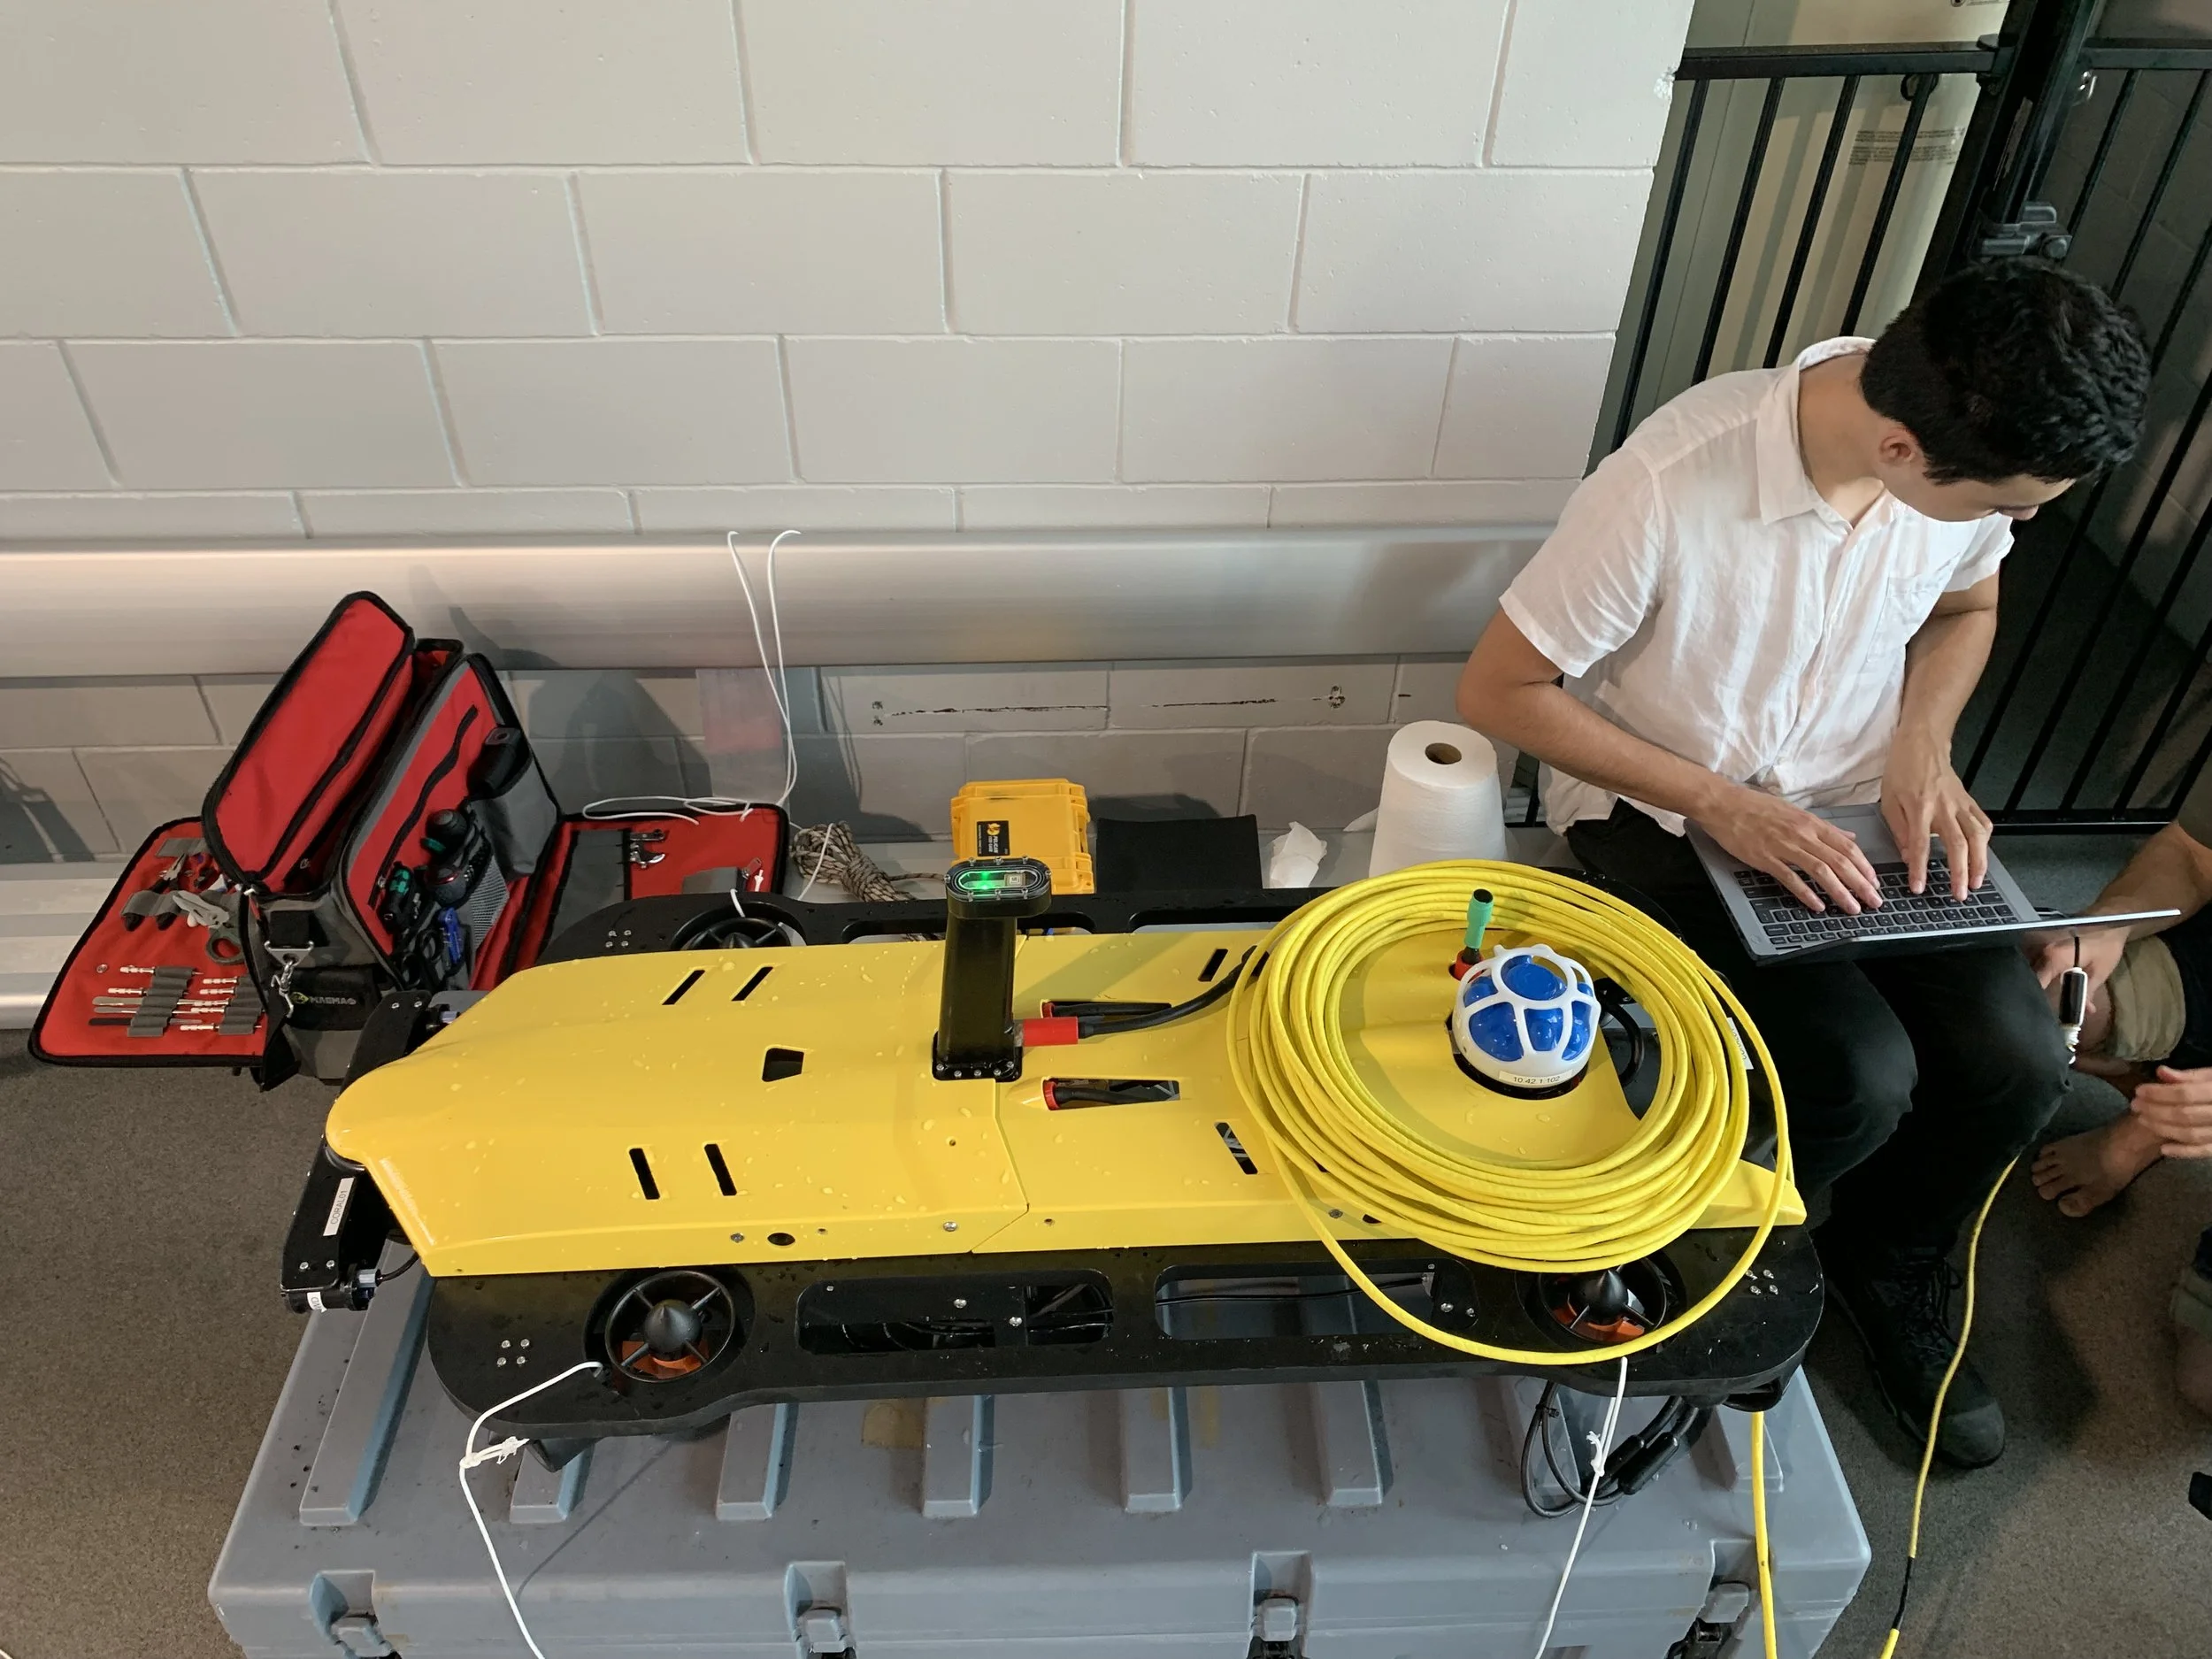
Cyborg worked with AIMS on the development of the REEFScan Deep AUV and the CoralAUV from August 2023 until June 2024. This included the following scope of work:
Electronics redesign of CoralAUV for robustness
Software architecture updates to incorporate new ROS modules and university code cleanup
Attitude controller for Deep AUV
Supporting other improvements identified during the product for future builds
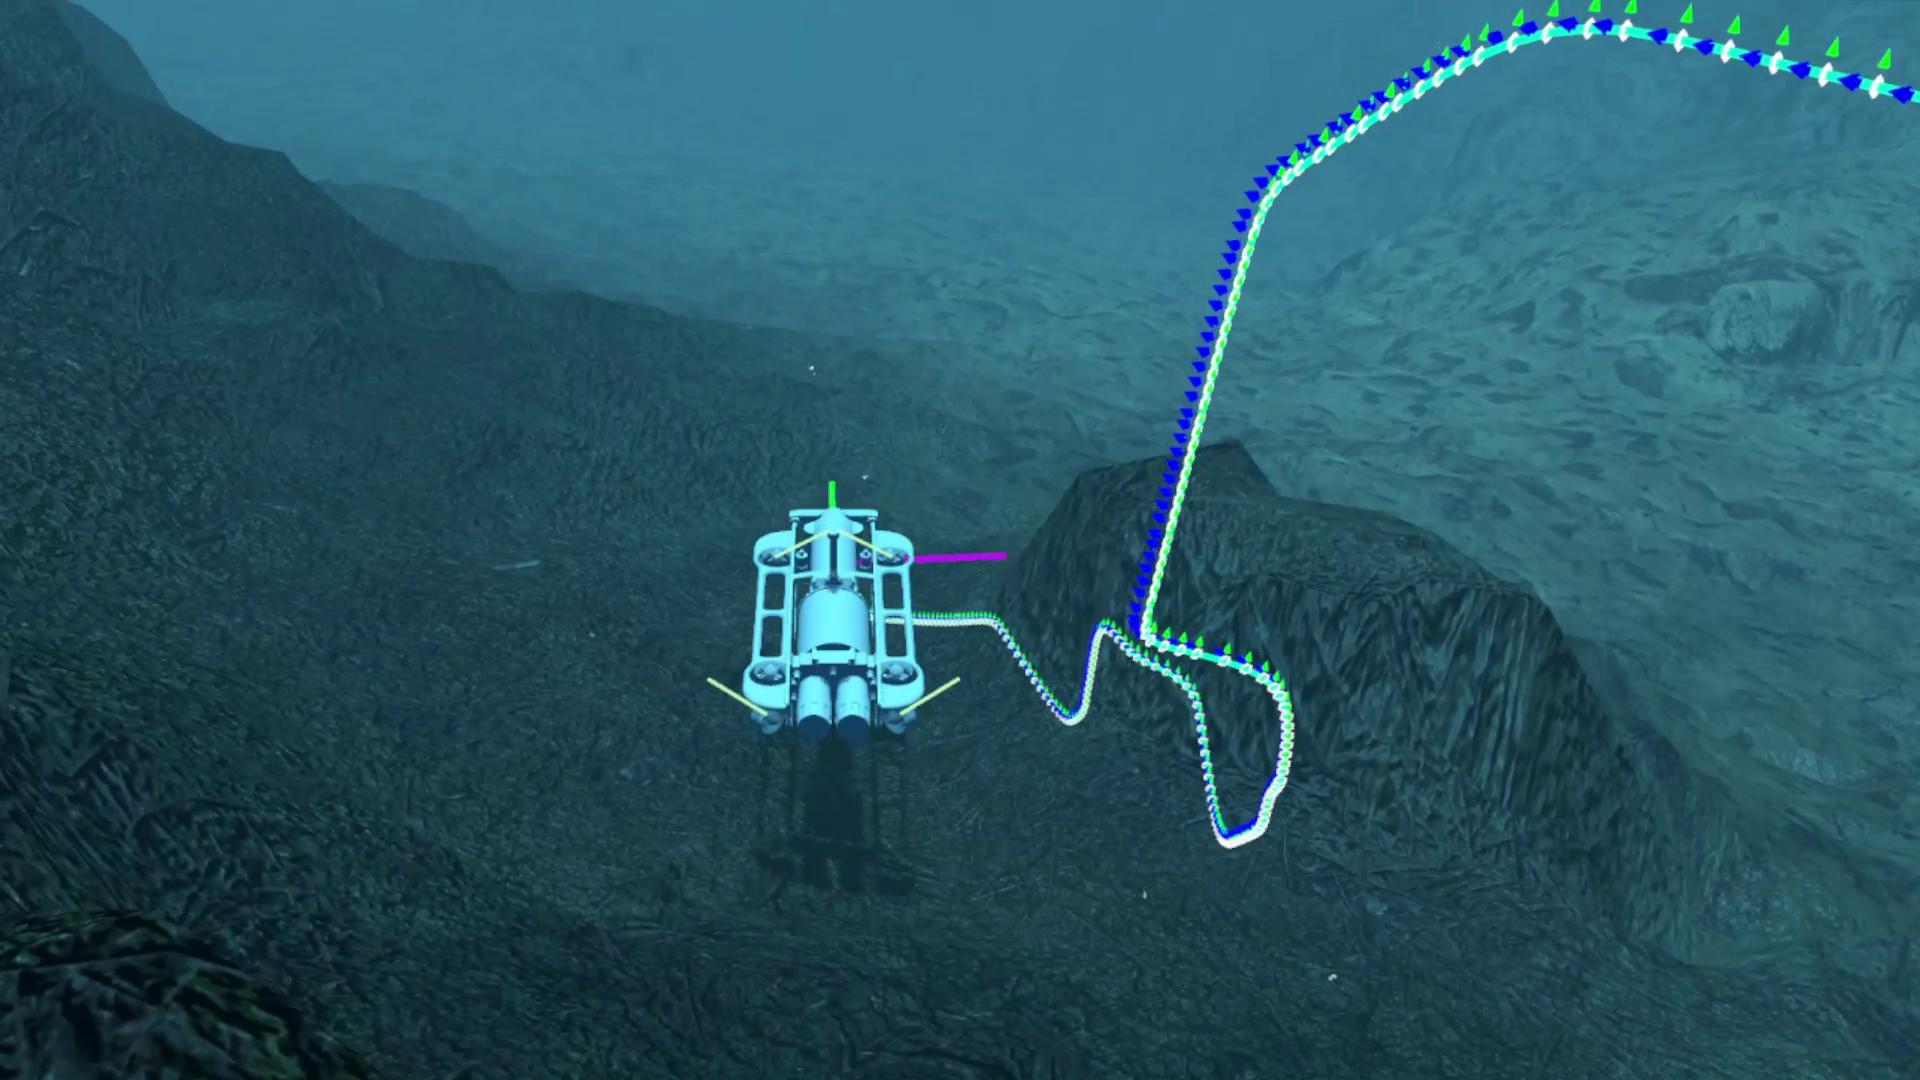
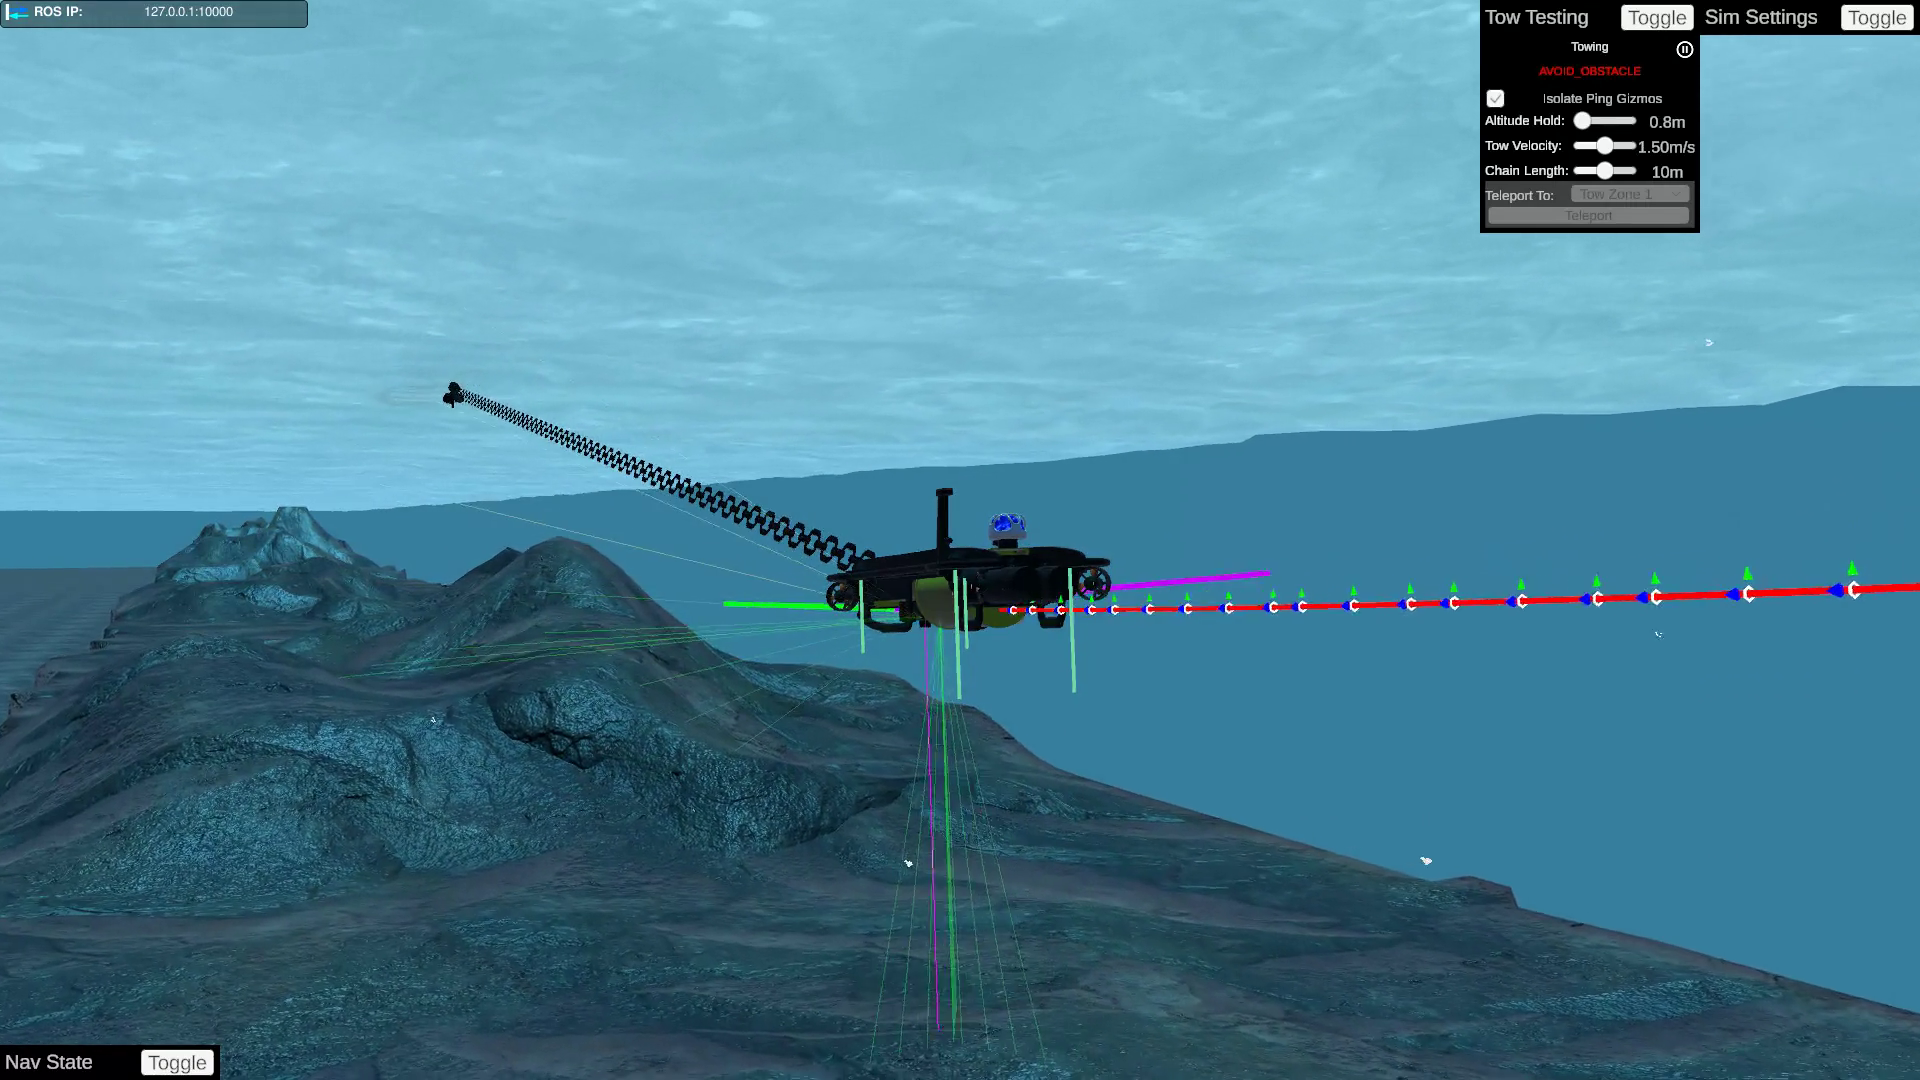
Collision avoidance development for Deep using 5 x sonar sensors
6DoF modelling and Software in the Loop for both platforms
User interface design updates
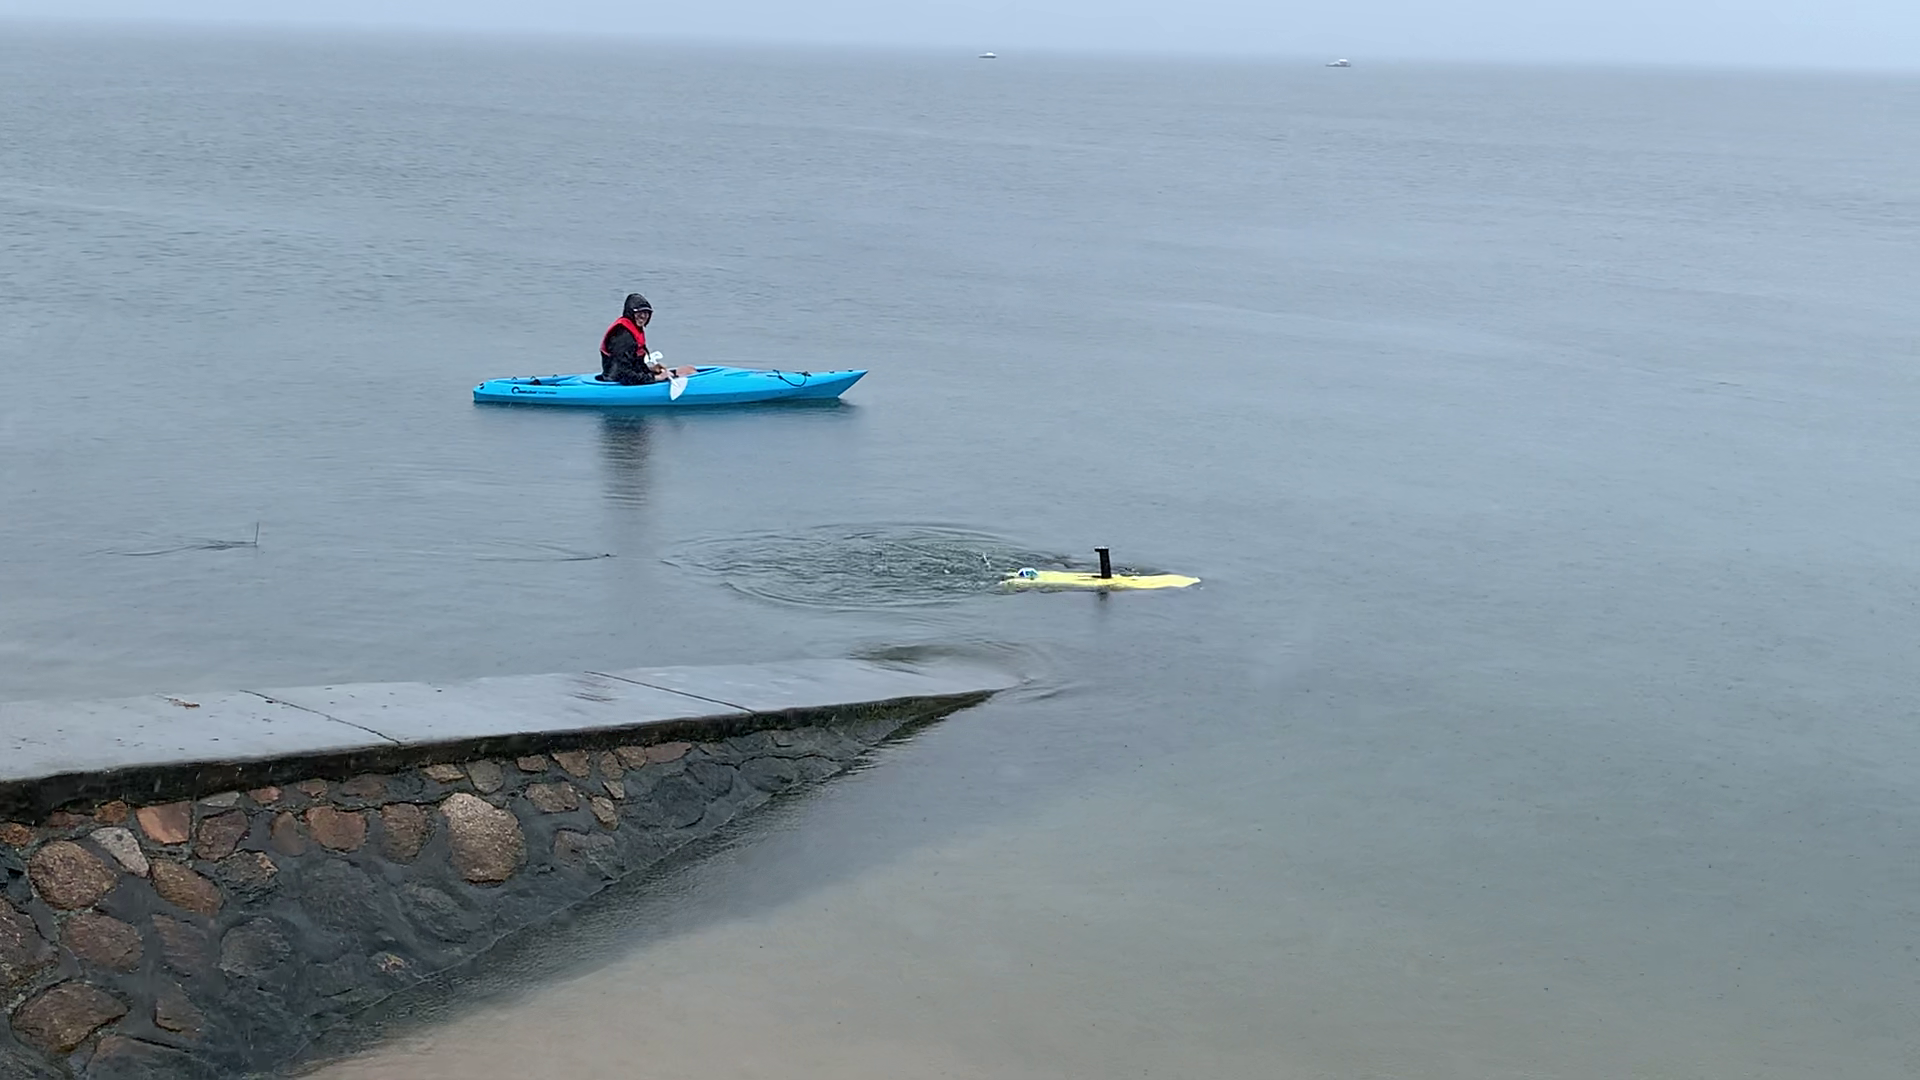
The project culminated with 30+ autonomous reef survey missions in the Great Barrier Reef in 2024, having started with non-operational AUVs.